DC Motor Position Controller: Meeting Settling Time with PID and Root Locus
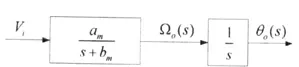
I designed a position controller for a DC servo motor in MATLAB. Under the requirements of a damping ratio of 0.4–0.7, a settling time under 1/30 s, and a phase margin of at least 40 degrees, I found the PID gains with the root locus, checked that the requirements were met and searched for the optimum, and wrote up my reflections.
 Sunhong'sSystem Blog
 Other Project